Lecture 09 Ch 6 (part II) Microprogrammed Architectures
Ryan Robucci
1. References
- \(\dagger\) [A Practical Introduction to Hardware Software Codesign] Patrick Shaumont
- Microprogramming Slides from [http://ece-research.unm.edu/jimp/codesign/]
2. FSMD vs Microprogram-Controlled Machine
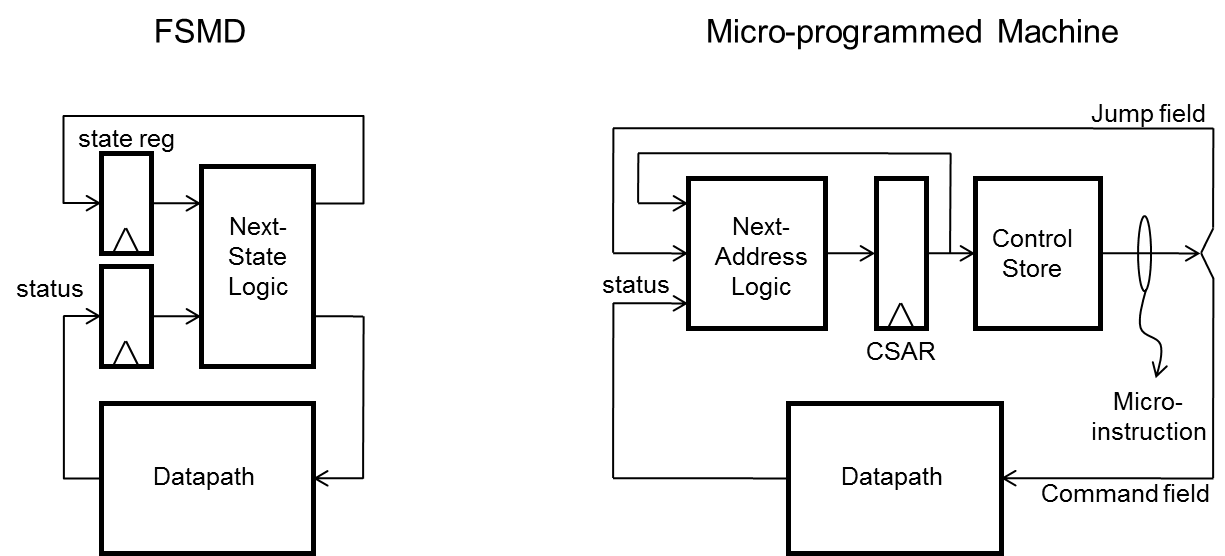
- With a microprogrammed machine, th next-state logic of FSM is replaced with a programmable memory called the Control Store
- The control store holds micro-instructions, and is addressed using a registered called a CSAR (Control Store Address Register)
-- †Shaumont
3. Microprogrammed Control
- CSAR is the equivalent of a program counter in a microprocessor
- Next-value of CSAR is determined by next-address logic, using
- current value of CSAR
- current micro-instruction
- value of status flags evaluated by the datapath
- Default next-state value is (CSAR + 1)
- In addition, next-address-logic implements conditional and absolute or relative jumps
- The next-address logic, the CSAR, and the control store implement the equivalent of an instruction-fetch cycle in a microprocessor
- From the figure, each micro-instruction takes a single clock cycle to execute since there is only one register
- Within a single clock cycle, the following activities occur:
- The CSAR provides an address to the control store which retrieves a micro-instruction
- micro-instruction has two parts:
- command-field serves as a command for the datapath
- jump-field 'points' to the next-address logic
- The datapath executes the command encoded in the micro-instruction, and returns status information to the next- address logic
- The next-address logic combines datapath states, micro-instruction jump-field and status returned from the datapath
- The next-address logic will eventually update the CSAR
- The critical path of the micro-programmed machine is determined by the delay through the control store, the next-address logic, and the datapath
4. Addressing Limitations of FSMD
- While the micro-programmed controller is more complicated than the
FSMD, it also addresses the problems of FSMDs very effectively:
- complexity
- exceptions
- control hierarchy
- flexibility/reprogrammablity
- The micro-programmed controller scales well with complexity
- For example, a 12-bit CSAR will allow a control store with up the 4096 locations, and therefore a micro-program with 4096 steps
- An equivalent FSM diagram with 4096 states, on the other hand, would be horrible to draw!
- A micro-programmed machine can deal efficiently with exception
handling, since global exceptions are managed directly by the
next-address logic
- For example, the presence of a global exception can feed a hard-coded value into the CSAR, immediately transferring control to an exception-handler
- Therefore, exception handling does not affect every instruction of a microprogram in the same way as it affects every state of a FSM
- A micro-programmed machine deals very well with control hierarchies
- Small modifications to the microprogrammed machine shown above allow pushing and popping of the CSAR for sub-routine calls
- Micro-programs are flexible and very easy to change after the
micro-programmed machine is designed
- Simply changing the contents of the control store is sufficient to change the program of the machine
- Here, there is a clear distinction between the architecture of the machine and the functionality implemented using that architecture
5. Microinstruction Encoding
- A key design choice is the format of micro-instructions in the control store
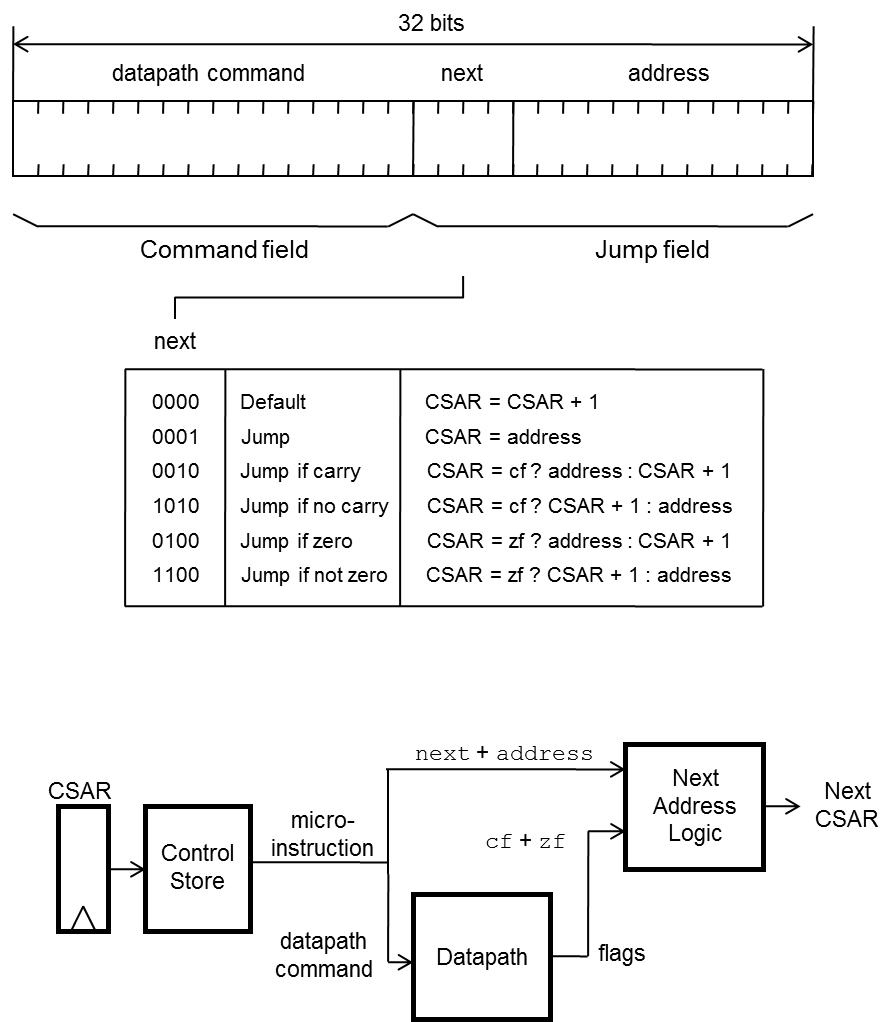
- A sample format for a 32-bit micro-instruction word is shown
-- †Shaumont
6. Jump Field
- Of the example 32-bit micro-instruction word, 16 bits are reserved for the datapath and 16 bits are reserved for the next-address logic
- The next-address field holds an absolute target address, pointing to a
location in the control store
- The address is 12 bit, which allows a control store as large as 4096 locations
- The next field encodes the operation that will lead to the next value
of CSAR
- As mentioned, the default operation is to increment CSAR
- For some instructions, the address field is unused
- Next field allows various jump instructions to be encoded
- Absolute jumps transfers the value of the address field into CSAR
- Relative Jumps transfers the value of the address field into CSAR
- A conditional jump will use the value of a flag to conditionally update the CSAR (or just increment it) it can also use absolute or relative program addressing
- Dedicating bits to the address field is wasteful
- In the example, 12 bits are dedicated to the address field
- Only about 1 in every 5 instructions is a jump
- There are ways to optimize this so that the address field bits are used for another purpose when the micro-instructions is not a jump instruction
7. Command Field
-- †Shaumont
- There are two approaches at micro- instruction encoding
- Horizontal microcode, where no or minimal decoding is required is done
- Vertical microcode, where the maximal amount of instruction encoding is done requiring more decoding
- A wide (horizontal) micro-instruction word allows each control bit of the data path to be stored separately
- A narrow micro-instruction word, on the other hand, will require the
creation of symbolic instructions, which are encoded groups of
control-bits for the datapath
- Therefore, a few bits of the micro-instruction define the value of many control bits in the data-path
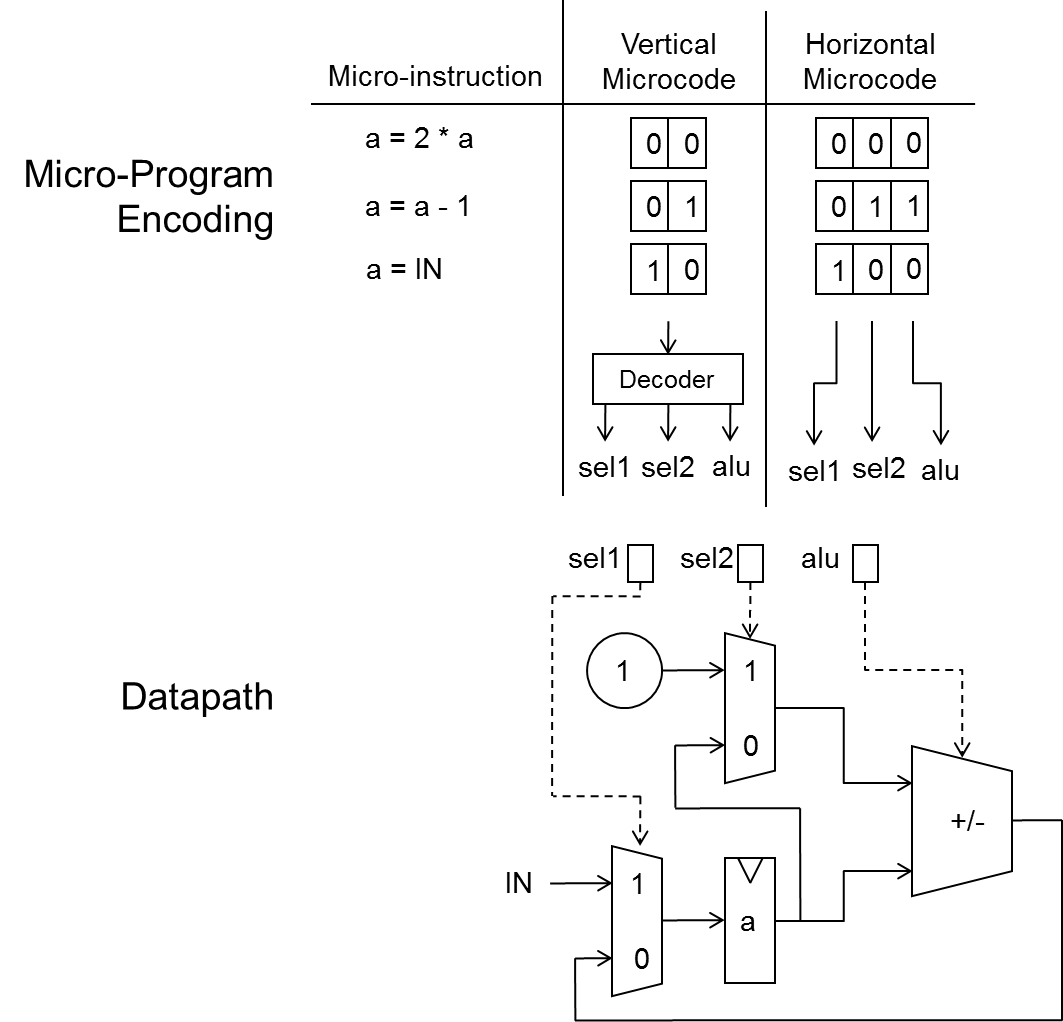
- Here, we create a micro-programmed machine with three instructions on reg a
- The three instructions do one of the following
- Double the value in a
- Decrement the value in a, or
- Initialize the value in a
- The datapath shown along the bottom of the figure contains two multiplexers and a programmable adder/subtractor
- The controller on top shows two possible encodings for the three instructions: a horizontal encoding, and a vertical encoding
- For horizontal, the control store includes each of the control bits in the datapath directly (3 bits)
- For vertical, the micro-instructions are encoded with a two-bit micro- instruction word, and a decoder is used
- So what is the design trade-off between horizontal and vertical microprograms?
- Vertical micro-programs have a better code density, which is
beneficial for the size of the control store.
- From the figure, the vertically-encoded version of the microprogram will be only 2/3rds of the size of the horizontally-encoded version
- On the other hand, vertical micro-programs use an additional level of
encoding, and need decoding before it can drive the control bits of
the datapath
- Thus, the machine with the vertically encoded micro-program may have a longer critical path
- In practice, designers use a combination of vertical and horizontal encoding concepts, so that the resulting digital structure is compact yet efficient
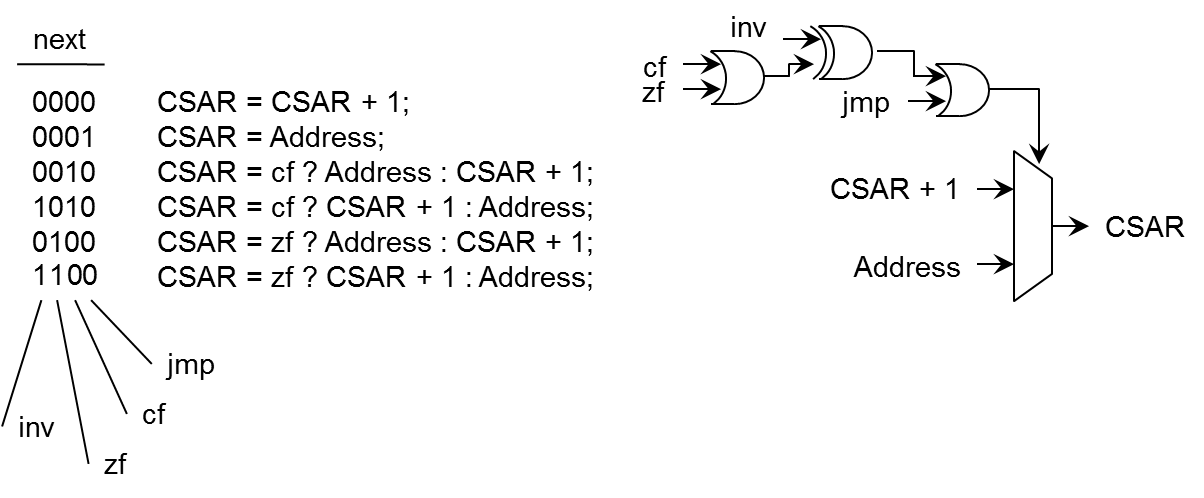
- Consider for example the value of the next field of the micro-instruction word
- There are six different types of jump instructions, which would imply that a vertical micro-instruction needs no more then three bits to encode these six jumps
-- †Shaumont
- Yet, four bits have been used, indicating that there is some redundancy
- The encoding was chosen to simplify the design of the next-address logic
- Another reason to leave "room" in the encoding is to allow future upgrades
- For example, easy to add an additional conditional jump that uses an arbitrary combination of cf and zf
8. Microprogrammed Datapath
- A datapath attached to the microprogrammed controller consists of
three parts (like the Datapath for the FSMD):
- Computation units such as adders, multipliers, shifters, and so on.
- Communications infrastructure (bus, crossbar, point-to-point connection, etc.)
- Storage, typically a register file or scratchpad RAM
- Each of these may contribute a few control bits to the micro-instruction word
- For example,
- Multi-function computation units have selection bits that determine their specific function, Storage units have address bits and read/write command bits
- Communication busses have source/destination control bits
- The datapath may also generate condition flags for the micro-programmed controller
9. Example Datapath Controller
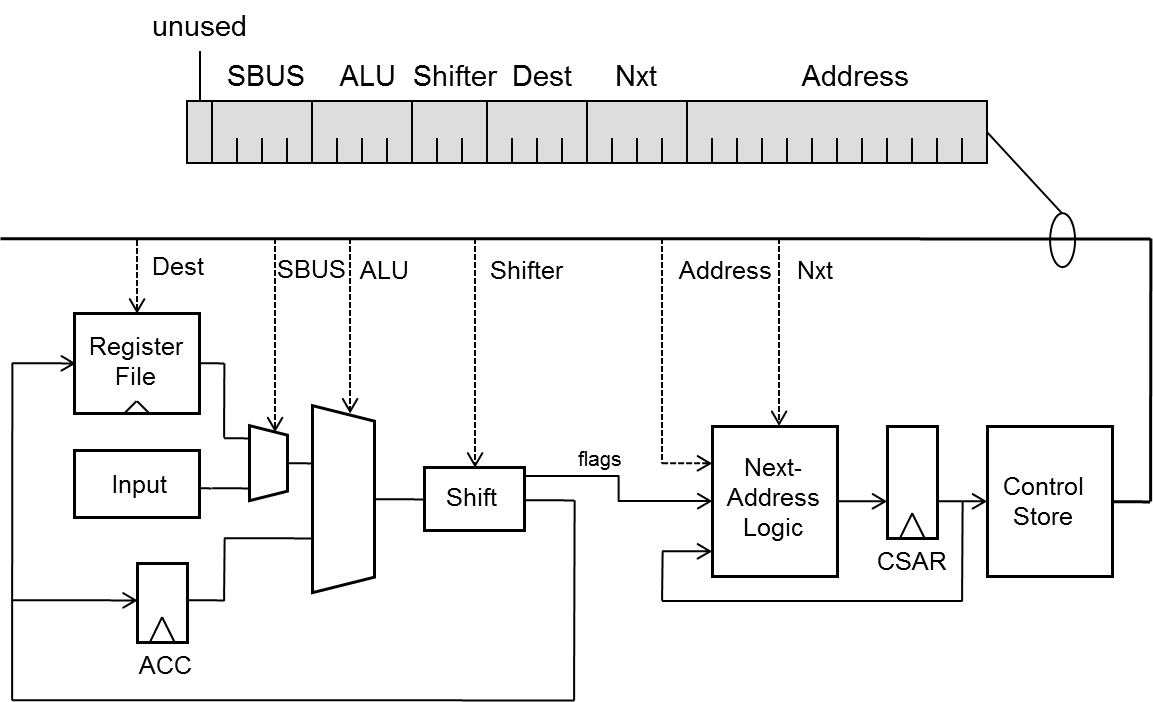
- Consider the micro-programmed controller with a datapath attached
- The datapath includes an ALU with shifter unit, a register file with 8 entries, an accumulator register, and an input port
-- †Shaumont
- The micro-instruction word contains 6 fields Nxt and Address are used
by the micro-programmed controller while the remaining fields are used
by the datapath. The type of encoding is mixed horizontal/vertical.
- The overall machine uses a horizontal encoding, i.e., each module of the machine is controlled independently
- The sub-modules within the machine use a vertical encoding, e.g., the ALU field contains 4 bits and can execute up to 16 different commands
Other characteristics:
- single instruction per clock cycle
- ALU operands
- inputs: accumulator and another from the reg. file or input port
- output: result sent to the reg file or accumulator
- datapath operation is controlled by 2 fields, SBUS (to specify source) and Dest (for result)
- The Shifter generates 2 flags, used by controller to implement conditional jumps
- A zero-flag: high when the output of the shifter is all-zero
- A carry-flag: which is defined as the most-significant bit
10. Writing Microprograms
-- †Shaumont
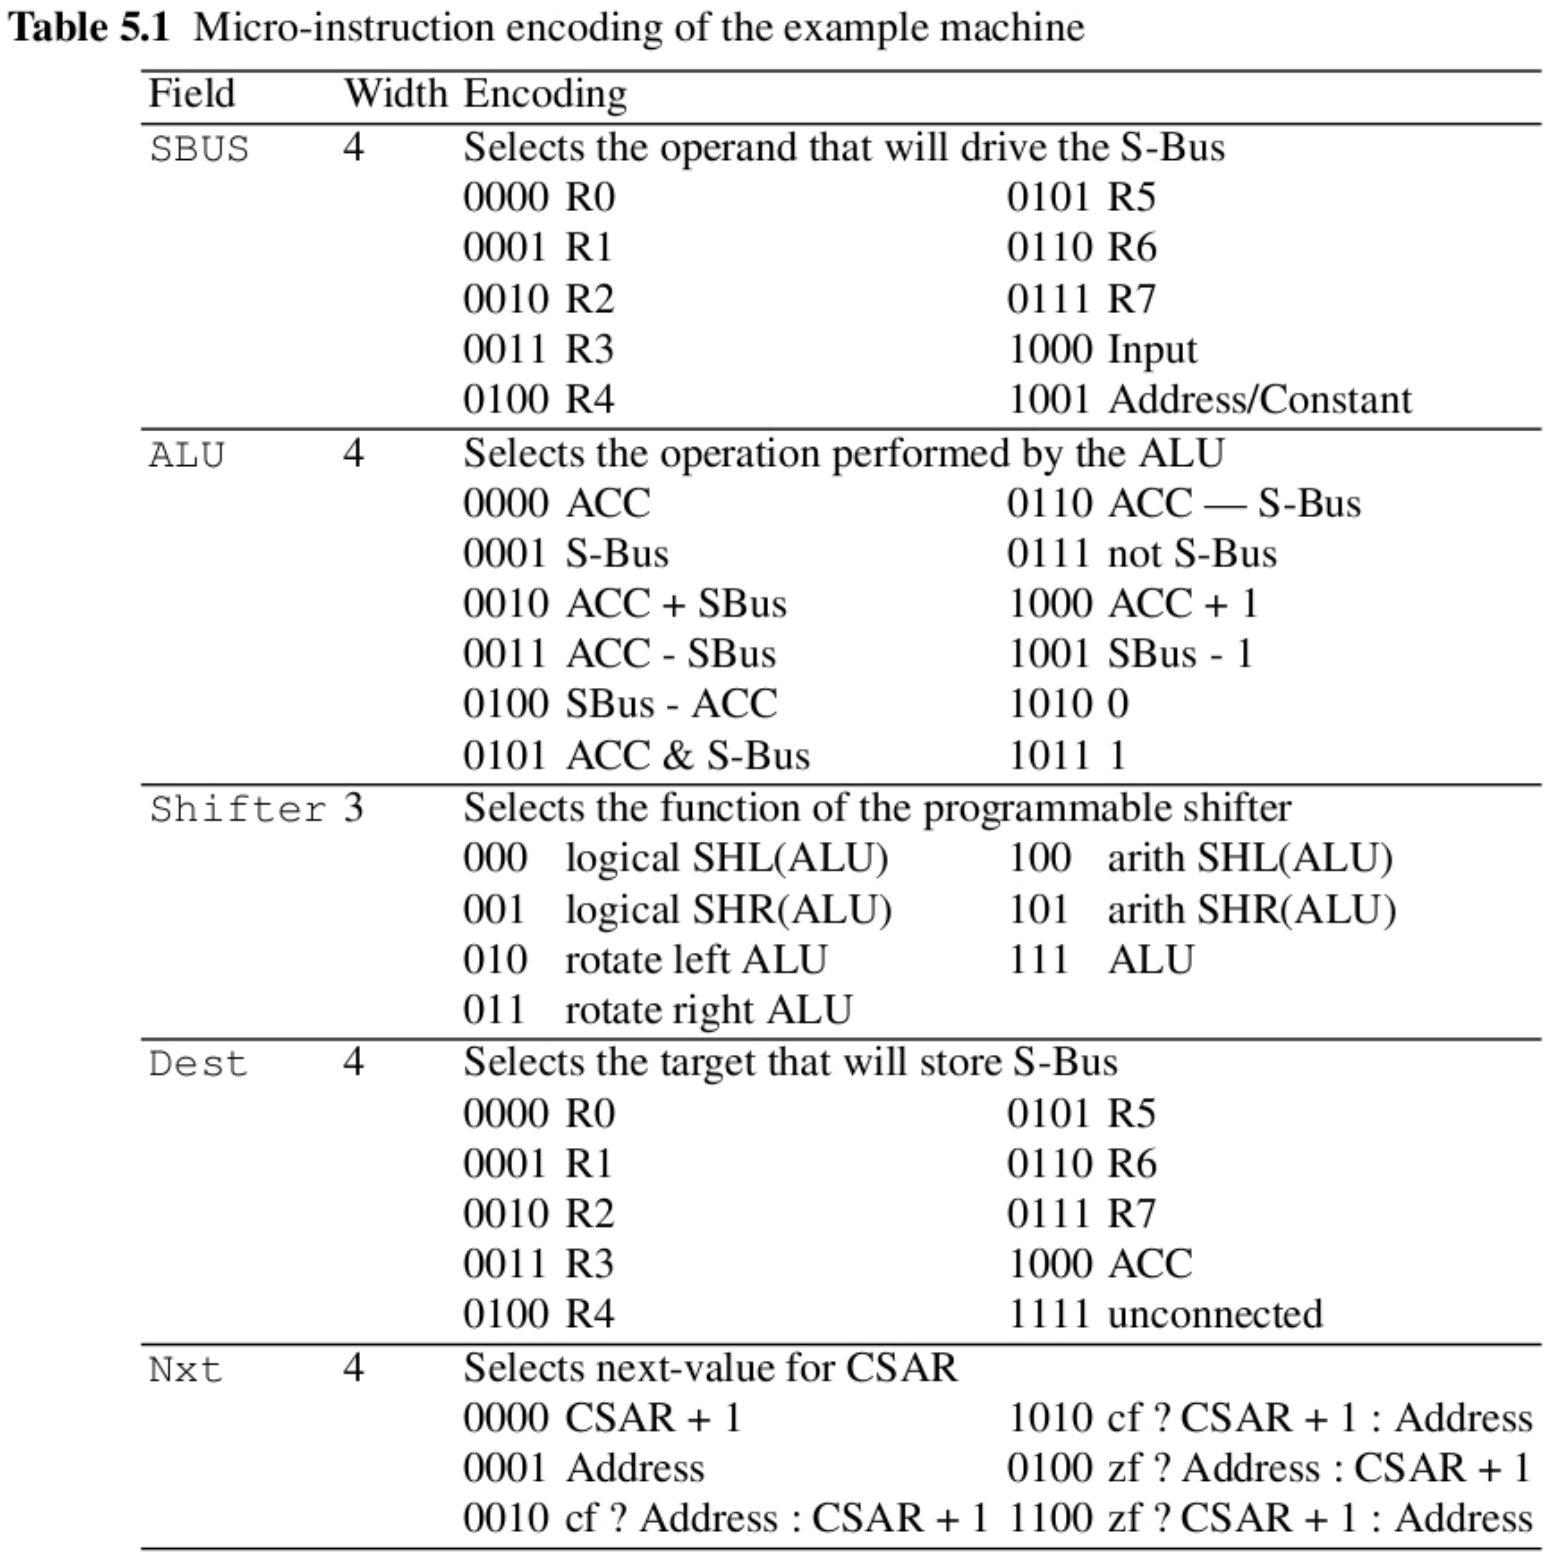
- table illustrates the encoding used by each module of the design
- A micro-instruction defines the module function for each module of the micro-programmed machine, including a next-address for the Address field
- When a field remains unused during a particular instruction, a don't care value can be specified
- The don't care values are designed to prevent unwanted state changes in the datapath
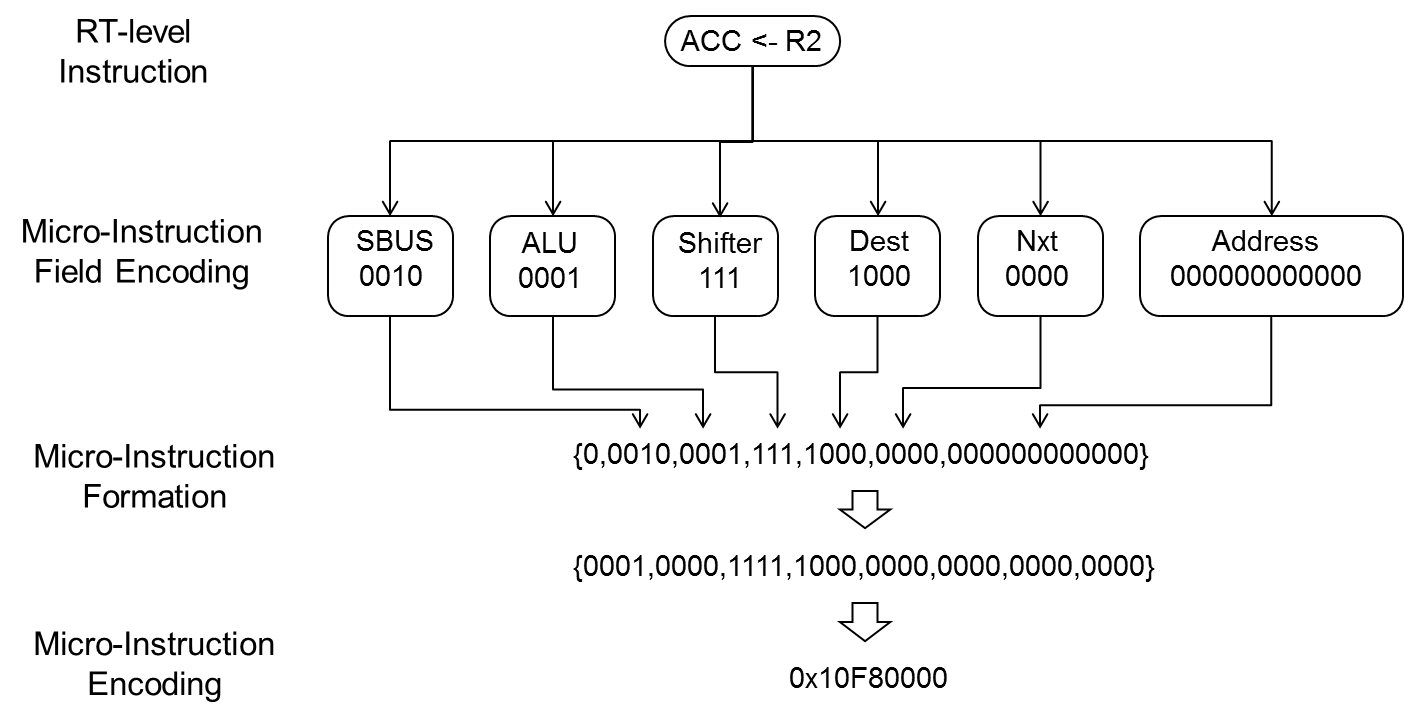
- For example, an instruction to copy register R2 into the accumulator
register ACC would be defined as follows
- The instruction gets the value in register R2 from the reg file, sends it over the SBus, through the ALU and the shifter, and to the ACC register
- This functional requirement determines the values in the
micro-instruction fields:
- The SBUS needs to transfer the value of R2, so (from the Table), the SBUS field is set to 0010
- The ALU needs to pass the SBUS input to the output, therefore, from the Table, the ALU field must be set to 0001
- The shifter passes the ALU output unmodified, thus the Shifter field is set to 111
- The output of the shifter is used to update the ACC, so the Dest field equals 1000
- There is no jump or control transfer for this instruction, so the
Nxt field is set to 0000 and the Address field is don't care
- The overall micro-instruction is assembled by putting all instruction fields together (as shown below) –0x10F80000
-- †Shaumont
- Writing a micro-program thus consists of formulating the desired behavior as a sequence of register transfers and then encoding them in the microinstruction fields
- Higher-level contructs, such as loops and if-then-else statements, are expressed as a sequence of register transfers
- Although this looks like a tedious task, bear in mind that the programmer has full control over the hardware at every clock cycle
Let's write the micro-program that implements Euclid's algorithm
1 ; Command Field           || Jump Field
2         IN -> R0
3         IN -> ACC
4 Lcheck: (R0 - ACC)        || JUMP_IF_Z Ldone
5         (R0 - ACC) << 1   || JUMP_IF_C LSmall
6         (R0 - ACC) -> R0  || JUMP Lcheck
7 Lsmall: (ACC - R0) -> ACC || JUMP Lcheck
8 Ldone:                       JUMP Ldone
Listing 6.1
- Lines 2 and 3 read in two values from the input port, and store them into registers R0 and ACC.
- At the end of the program, the resulting GCD will be available in
either ACC or R0
- The exit condition is implemented in line 4, using a subtraction of two registers and a conditional jump based on the zero-flag
- When the registers have different values, the program continues to subtract the largest one from the smallest one
- The larger value stored in R0 and ACC is determined by line 5, a
conditional jump
- The "bigger than" test is implemented using a subtraction, a left-shift and a test on the resulting carry-flag
- If the carry-flag is set, then the most-significant bit of the subtraction would be one, indicating a negative result in two's complement
- This instruction is a conditional jump-if-carry, and is taken if R0 is < then ACC
- Lines 4, line 5 and line 6 implement an if-then-else stmt using multiple conditional and unconditional jump instructions
- Book gives Example of a Micro-programmed Machine with hardware and
microcode software in GEZEL
- The design is itself an example of how the FSMD model can be applied to create a more complex micro-programmed machine
- Next, we show how this can be used to create programming concepts at even higher levels of abstraction, using micro-program interpreters
11. Micro-program Interpreters
- A micro-program is a sequence of commands highly-optimized for a datapath
- Writing efficient micro-programs for a given machine architecture requires an in-depth understanding of the specific machine architecture and its datapath – this represents some learning overhead over the programmer
- If a pseudo-assembly language and custom “assembler” are created with the architecture it makes coding coding easier
- As opposed to implementing complete applications as microcode, common usage of micro-programs is to serve as interpreters for other programs developed at a higher abstraction level, implementing some subset of
required features (example: implement multiplier over several clock cycles using adder and shifter)
- An interpreter is a machine that decodes and executes instruction sequences of an abstract high-level machine – a macro-machine
- The instructions from the macro-machine will be implemented as micro-programs
- A micro-program interpreter is designed as an infinite loop
- It reads a macro-instruction byte and decodes it into opcode and operand fields
- It then takes specific actions depending on the values of the opcode
12. A microprogram Interpreter
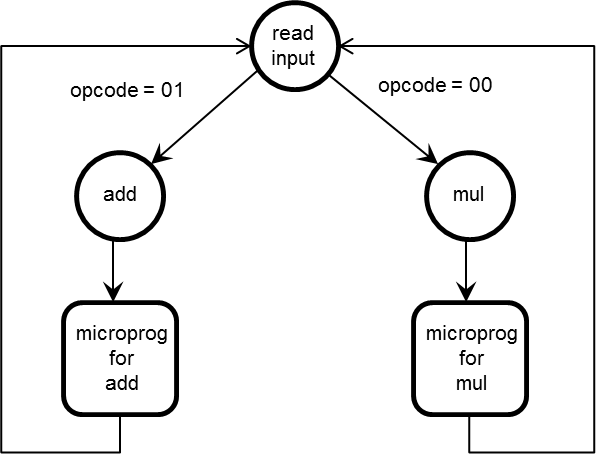
-- †Shaumont
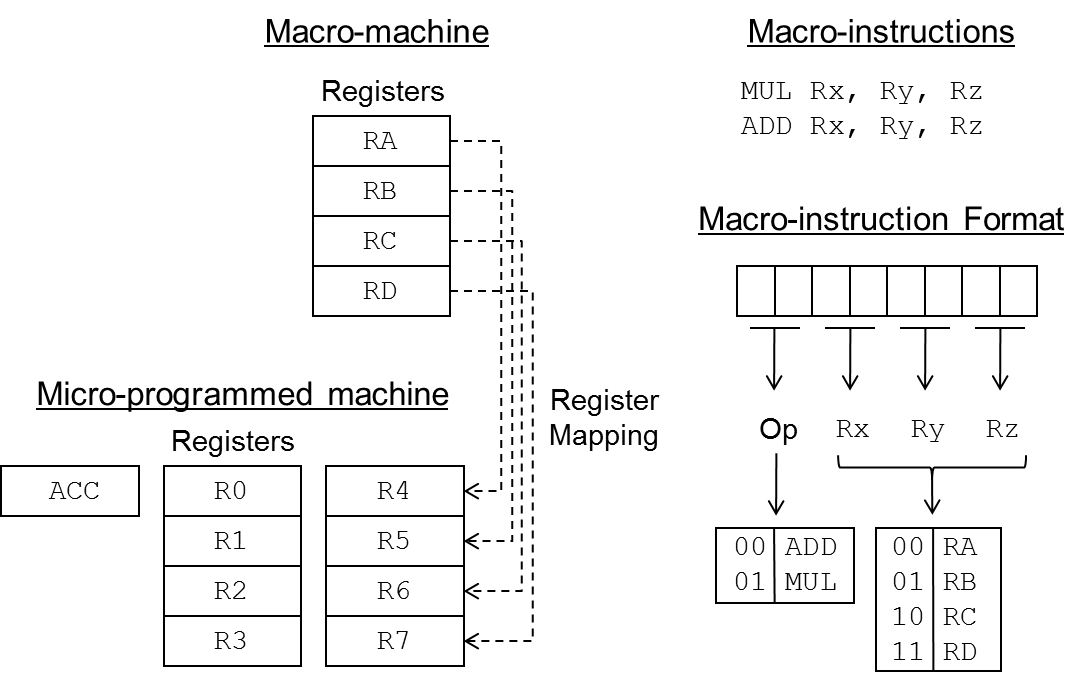
- Consider the following simple machine as a programmers' model of a macromachine
- It has four registers RA through RD, and two instructions for adding and multiplying those registers
- The macro-machine has the same wordlength as the micro-programmed machine but has fewer registers than the micro-programmed machine
- To implement the macro-machine, we map the macro-register set directly onto the micro-register set (as shown right)
- This leaves register R0 to R3, and the accumulator, available to implement macroinstructions
- The macro-machine has two instructions: ADD and MUL, which take two source operands (in the macro-machine registers) and generates one
- The micro-machine needs a decoder for macro-instructions (which are 1
byte wide)
- The format is two bits for the macro-opcode, and two bits for each of the macroinstruction operands
- A micro-programmed interpreter can create the illusion of a machine that has more powerful instructions than the original micro-programmed architecture
- The microprogram itself may require multiple cycles to complete the multiple micro-machine instructions required to implement a single macro-machine instruction, complicating the coding process
- The concept of micro-program interpreters has been used extensively to design processors with configurable instruction sets, and was originally used to enhance the flexibility of expensive hardware
- Today, the technique of micro-program interpreter design is still very useful for creating an additional level of abstraction on top of a micro-programmed architecture
13. Microprogram Pipelineling
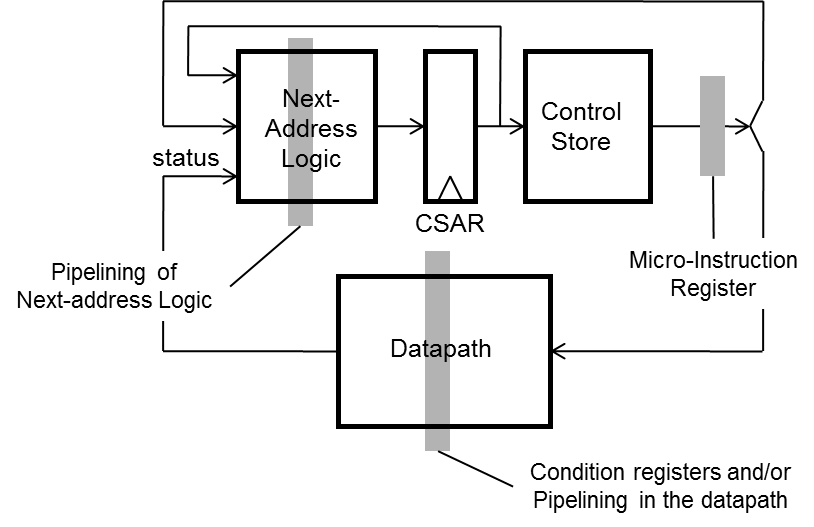
- Pipeline registers can be used to break up the micro-program controller logic
- However, adding pipeline registers has a large impact on the design of micro-programs
- Each choice cutes through a different update-loop of the CSAR register
- through the next-address logic,
- through the control store and the next-address logic
- through the control store, the data path, and the next-address logic
- These combinational paths may limit the maximum clock frequency of the microprogrammed machine
-- †Shaumont
- There are three common places where pipeline registers may be inserted, as shown above with shaded boxes
- At the output of the control store as a micro-instruction register
- Inserting a register there allows temporal overlap of the datapath evaluation, the next address evaluation, and the micro-instruction fetch
- In the datapath to create a datapath pipeline
- Common to have condition-code registers can be inserted on datapath outputs (status registers)
- In the next-address logic
- in case high-speed operation is required and the target CSAR address cannot be evaluated within a single clock cycle
- At the output of the control store as a micro-instruction register
(i) Micro-instruction Register
-- †Shaumont
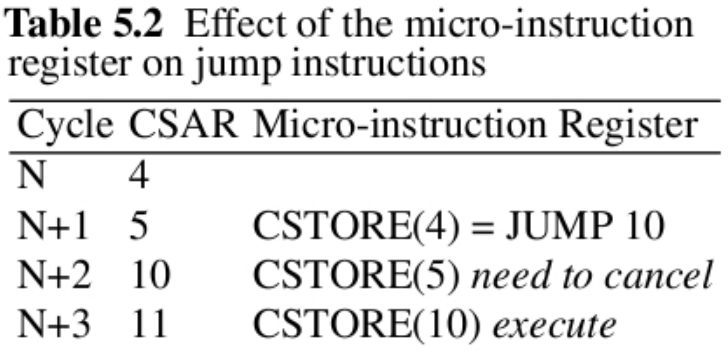
- Consider the effect of including a micro-instruction register
- With this register in place, micro-instruction fetch is offset by one cycle from evaluation micro-instruction
- For example, when the CSAR is fetching instruction i, datapath and nextaddress logic executing instruction \(i-1\)
- Consider this offset under the condition that the instruction stream contains a jump instruction
- The micro-programmer entered a JUMP 10 instruction in CSTORE location 4, and which is fetched in clock cycle N
- In clock cycle N+1, the micro-instruction will appear at the output of the microinstruction register and its execution will complete in cycle N+2
- For a JUMP, this means that the CSAR should NOT point to the next instruction in cycle N+2, but the instruction at N+2 has already been fetched
- To avoid a wasted execution cycle (e.g. no-op after branch) the platform should support
- delayed execution slot (delayed branch concept) is an instruction that may be executed independent of the branch instruction
- A compiler may handle this by choosing an appropriate instruction to reorder otherwise the programmer would need to handle this
- ability to cancel execution of instruction (dependent on branch decision)
- delayed execution slot (delayed branch concept) is an instruction that may be executed independent of the branch instruction
(ii) Datapath Condition-Code Register
-- †Shaumont
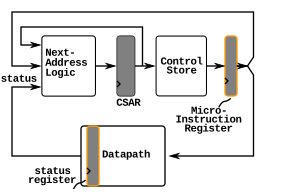
- Assume that we have a condition-code register in the datapath, in addition to a microinstruction register
- The fact that it is a register means that the actual condition code will not be available in the current clock cycle (when the expression is evaluated)
- Therefore, conditional-jump instructions can only operate on datapath conditions from the previous clock cycle
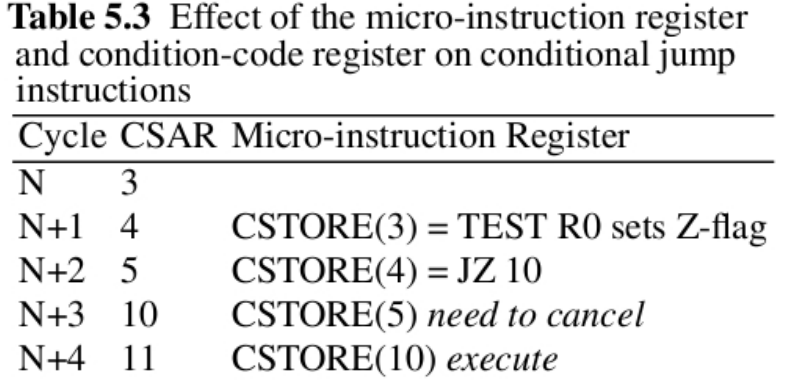
- Here, the branch instruction in CSTORE(4) is a conditional jump
- When the condition is true, the jump will be executed with one clock cycle delay
- The JZ instruction implements the jump in cycle N+2, which tests the condition code generated in cycle N+1 and which becomes available in N+2
- Here, the micro-programmer just needs to be aware that condition flag must be generated one clock cycle before they are used in conditional jumps
- note in the microprogram how "CSTORE(3)" generates the flag that is used by "CSTORE(4)=JZ 10"
- Note instruction at N+3 needs to be canceled if jump is taken
(iii) Pipelined Next-Address Logic
-- †Shaumont
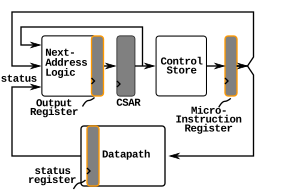
- Assume that there is a third level of pipelining available inside of the next-address update loop
- For simplicity, we will assume there are two CSAR registers back-to-back in the next-address loop
- The output of the next-address-logic is fed into the CSAR pipeline register and the output of CSAR pipeline register is connected to CSAR
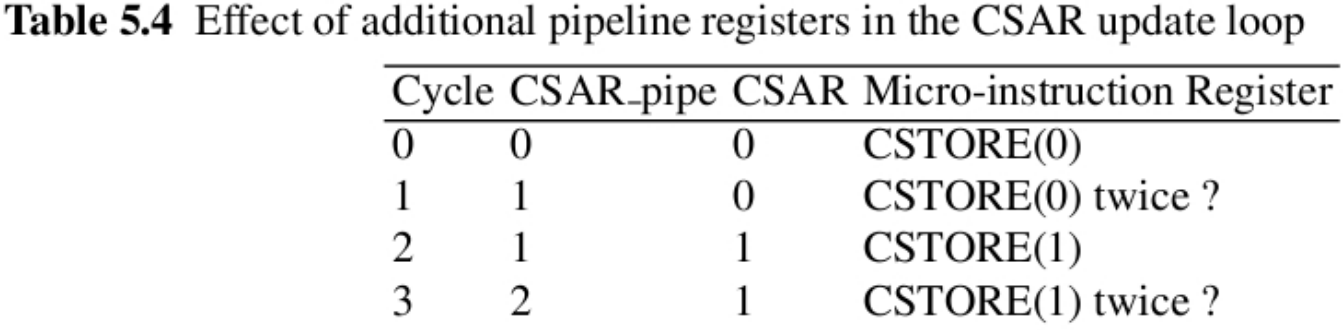
- Assuming all registers are initially zero, the two CSAR registers in the next-address loop result in two (independent) address sequences
- Each instruction of the micro-program is executed twice!
-- †Shaumont
- careful initialization of CSAR pipe and CSAR needed such that they start out at different values (e.g. 1 and 0)
- Unfortunately, special load needs to be done for each jump instruction too
- This complicates the design and the programming of pipelined next-address logic
14. Complexity for Programmer
- These examples show that a micro-programmer must be aware of the implementation details of the micro-architecture
- In particular, he/she MUST be aware of all the delay effects caused by registers
- This significantly increases the complexity of the development of micro-programs
- A possible approach is to develop a custom language and/or compiler